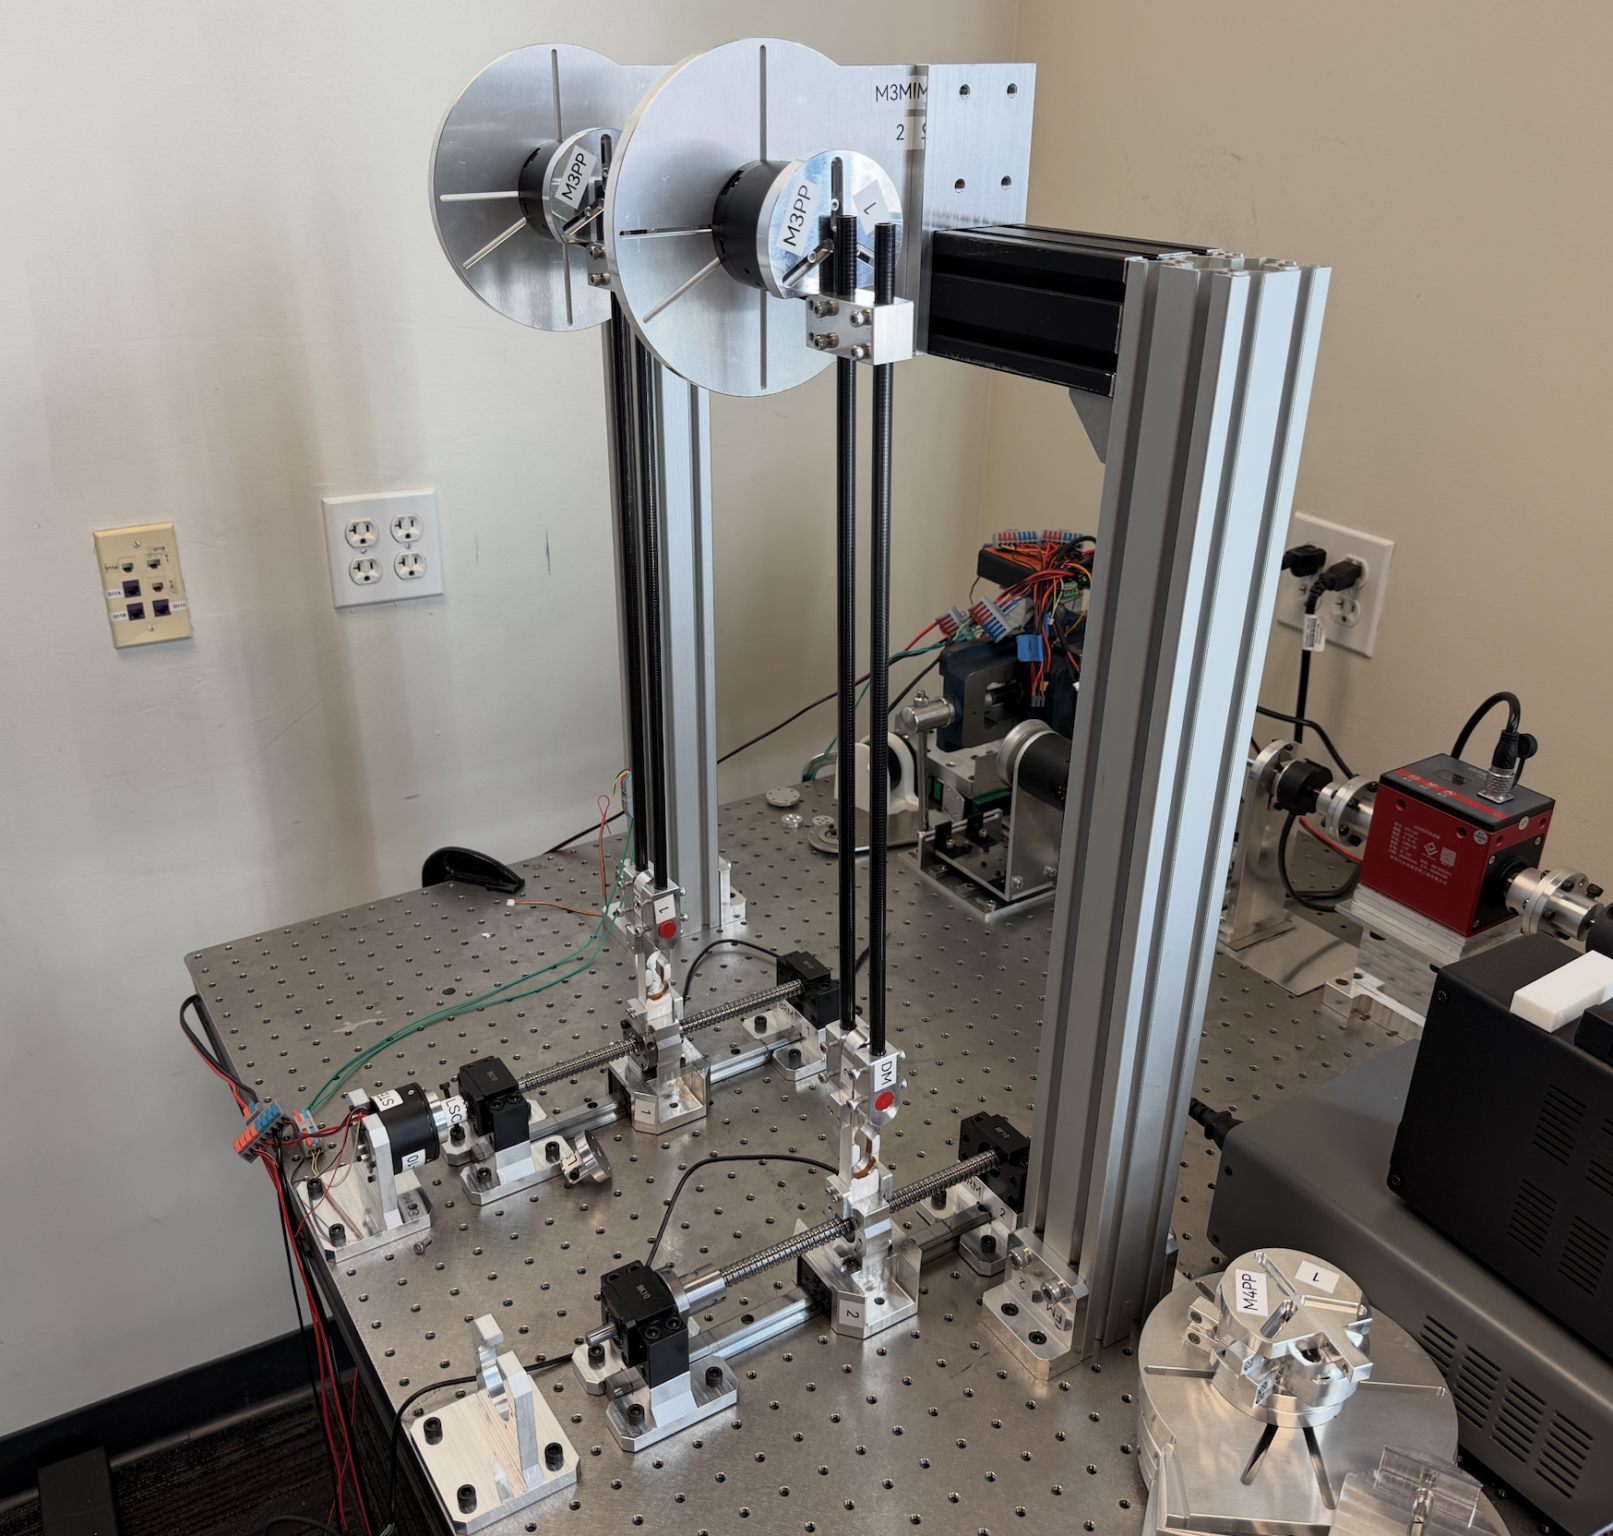
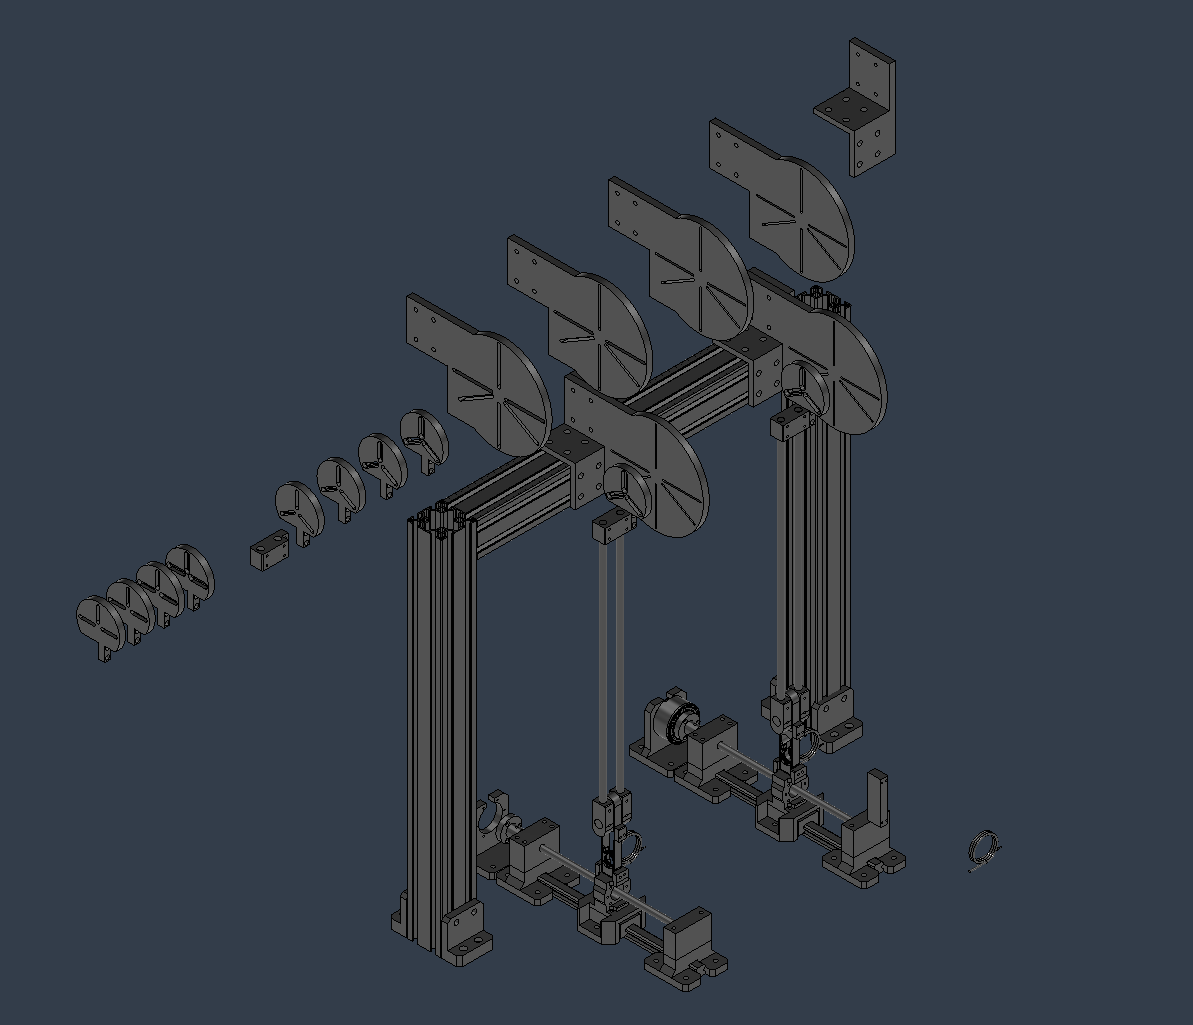
At Mundane Systems, I designed and built a rig to measure how accurately a teleoperation system reproduces force feedback, independently of its motor signals.
Paired motors connect through carbon-fibre arms to load cells on linear stages. A motor-driven lead screw moves the follower while the leader stays fixed, letting the team compare both sides’ responses across different test motions.
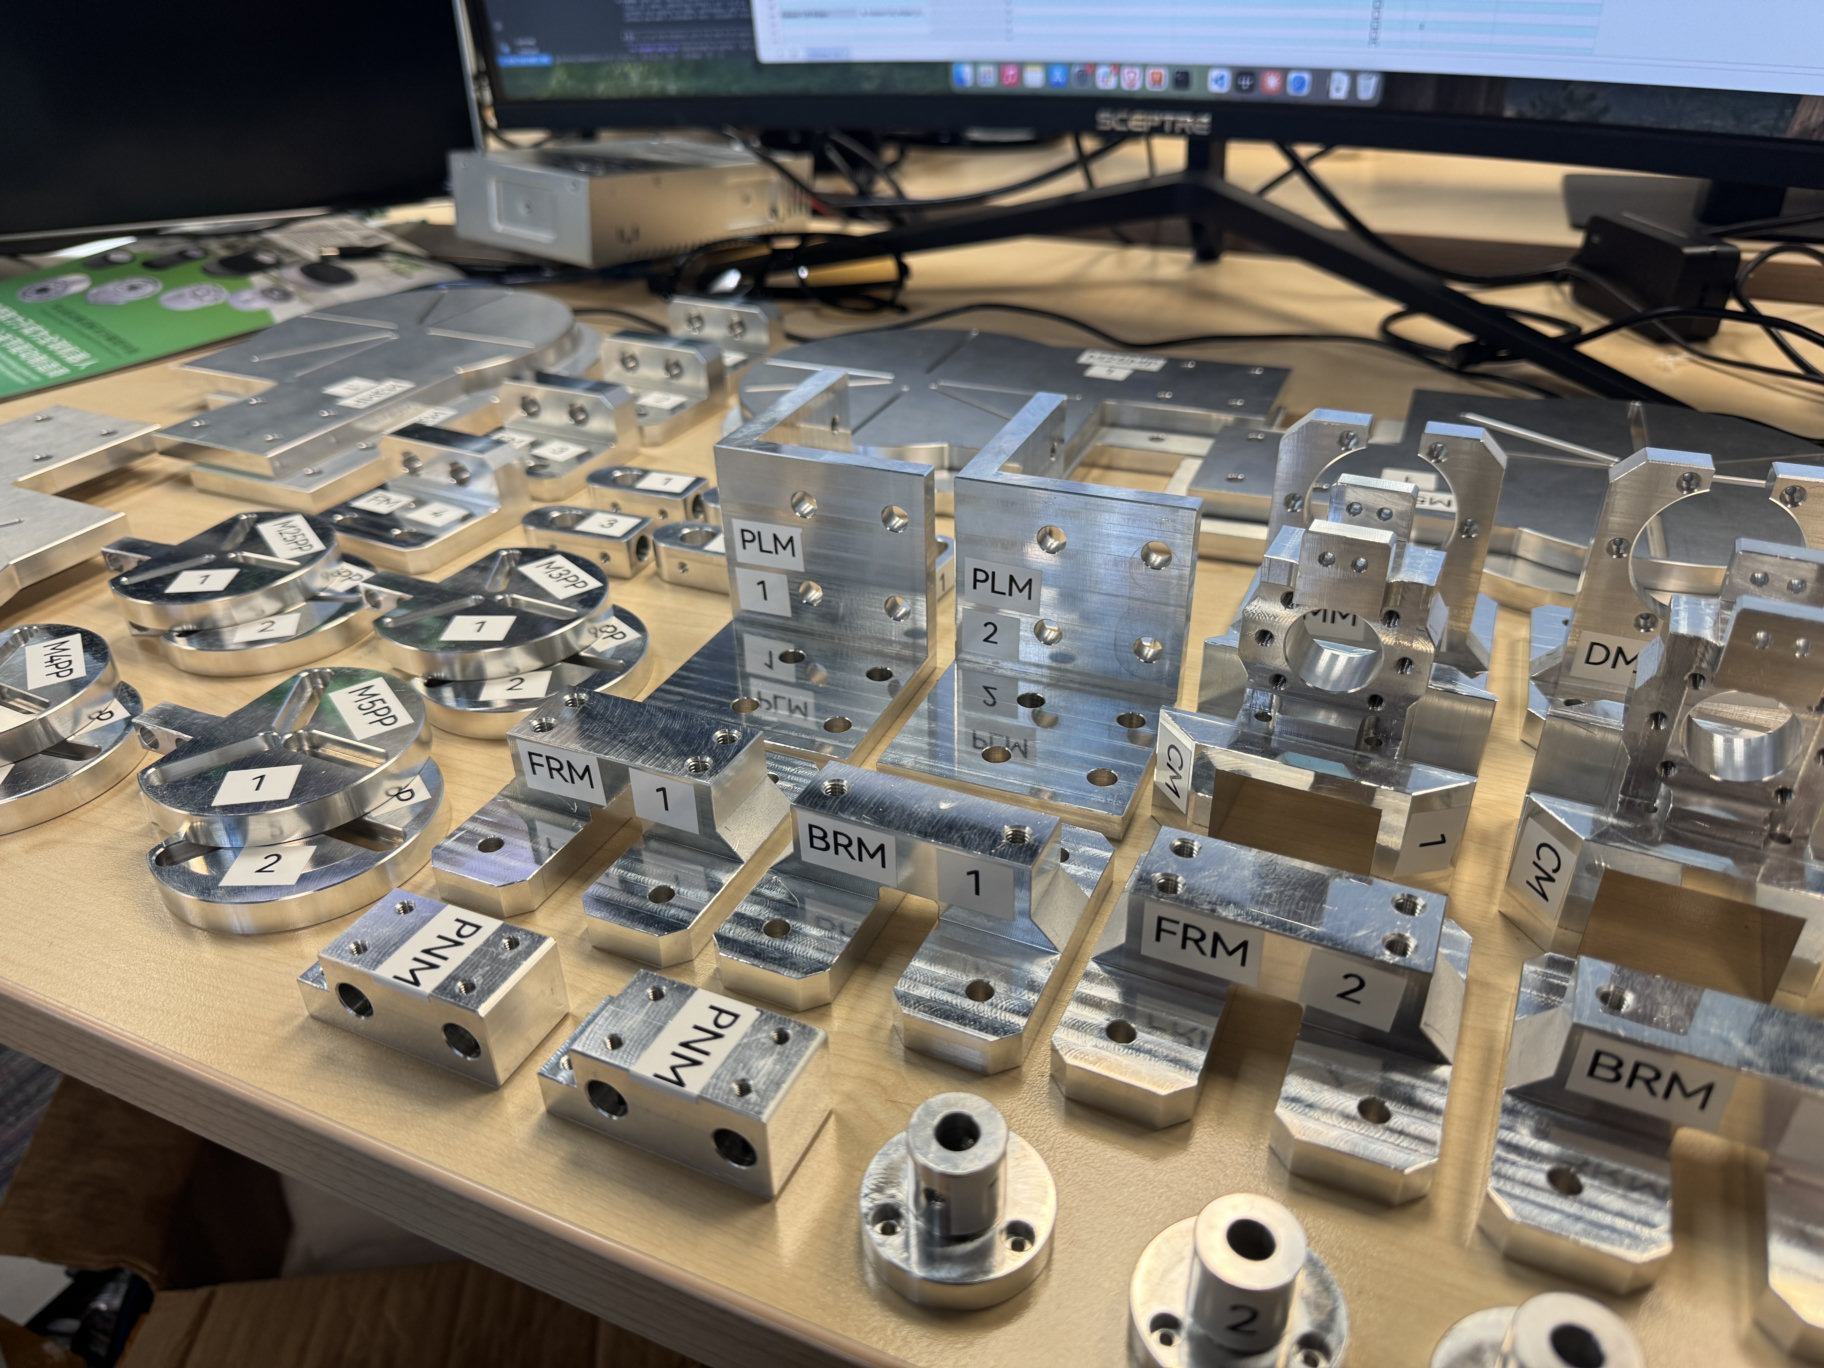
I owned the Fusion 360 design, custom CNC-machined parts, DFM/DFA, and GD&T drawings, then helped integrate the hardware with the team’s software. Completed in June 2026, the rig was handed over for haptics testing; the team owned the algorithms and subsequent experiments.