Arm integration, Ethernet teleoperation, and headset-driven neck controls.
Date 08 September 2026
Role Controls Engineer — Mundane Systems Inc.
Contribution Software development
Skills C++, Python, ROS 2, Pinocchio, URDF, CAN, Gravity compensation, PD control, Hardware integration
At Mundane Systems, I helped bring new robot arms into the existing leader–follower system and tuned the headset-driven neck.
Arm bring-up
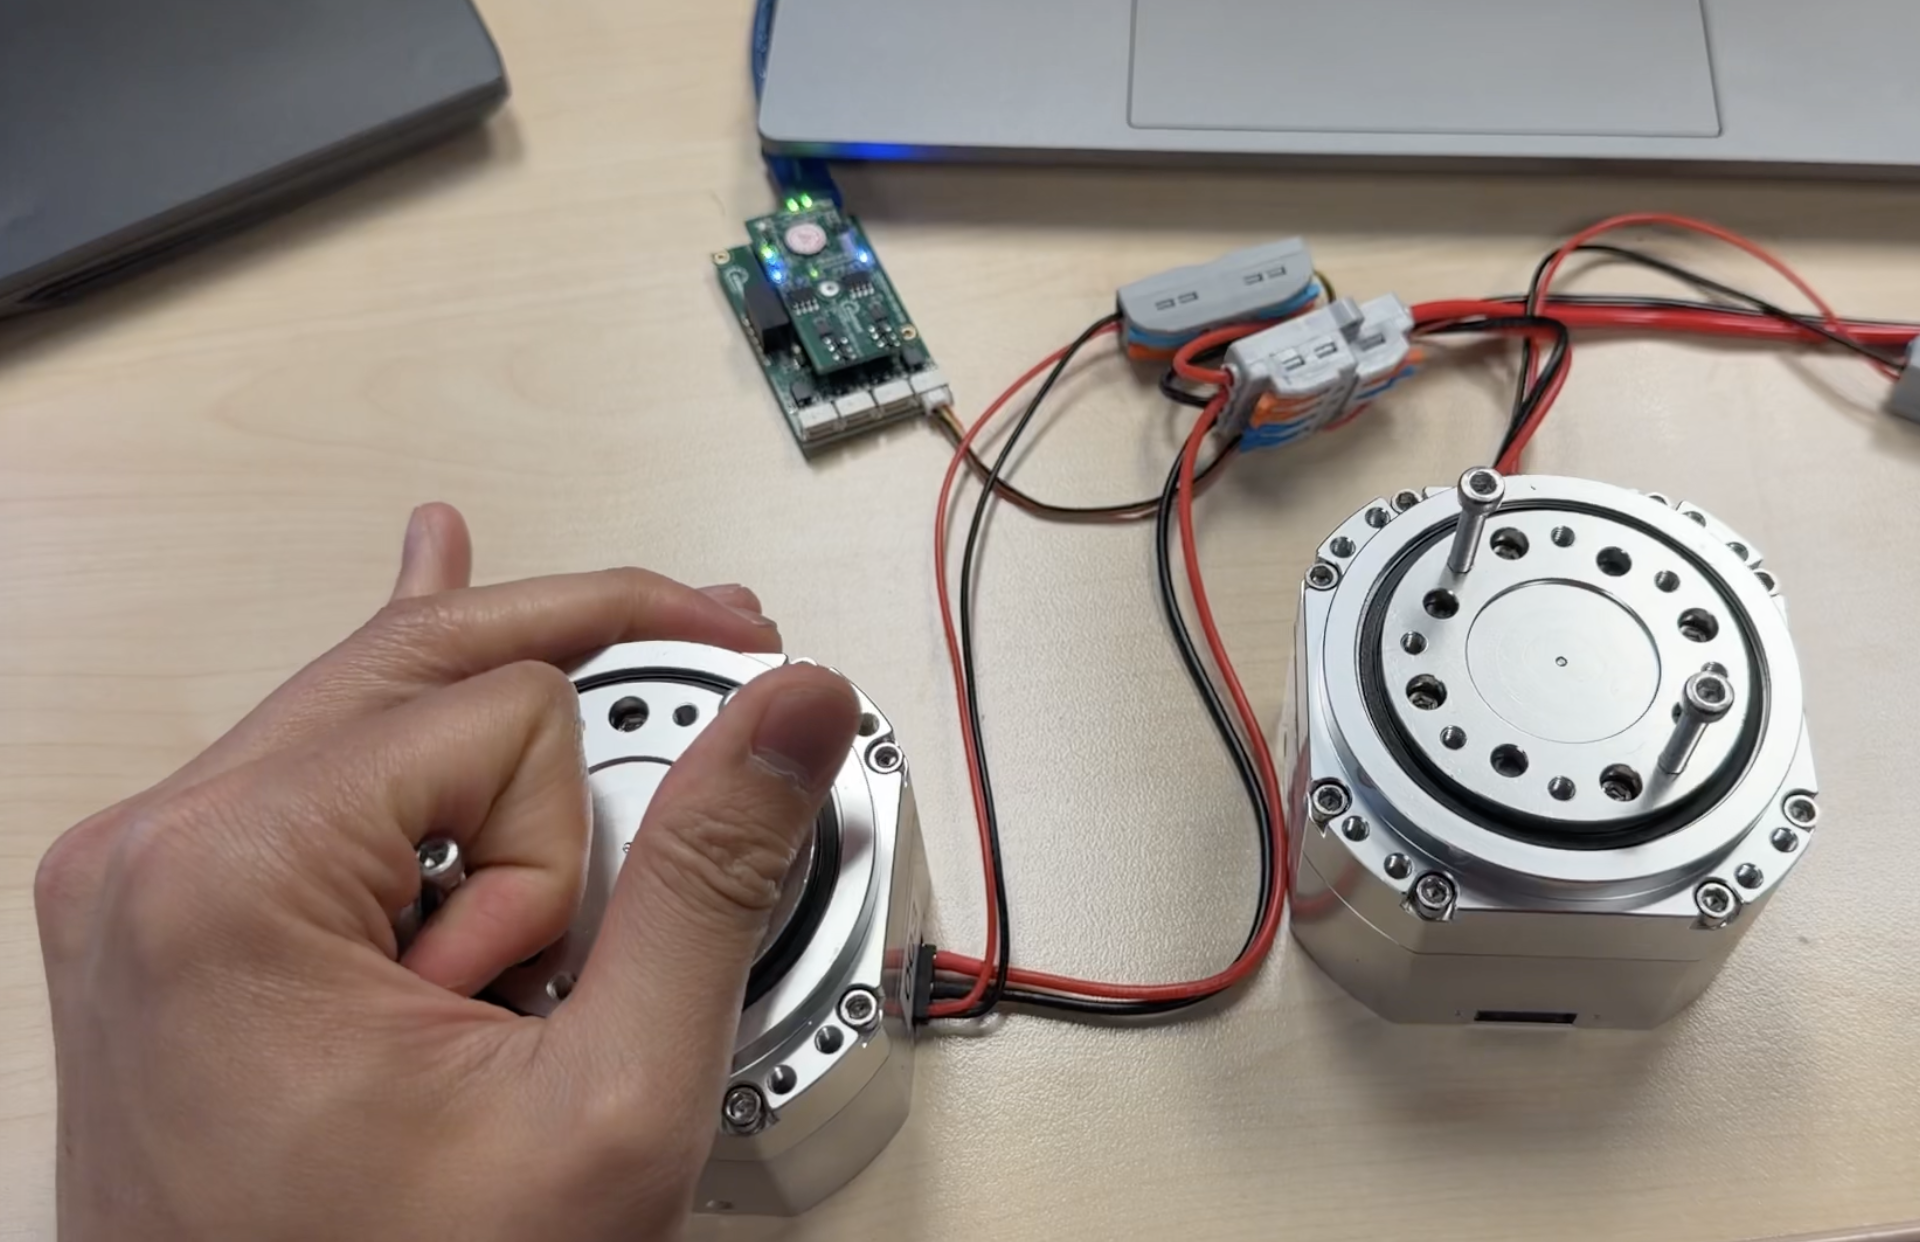
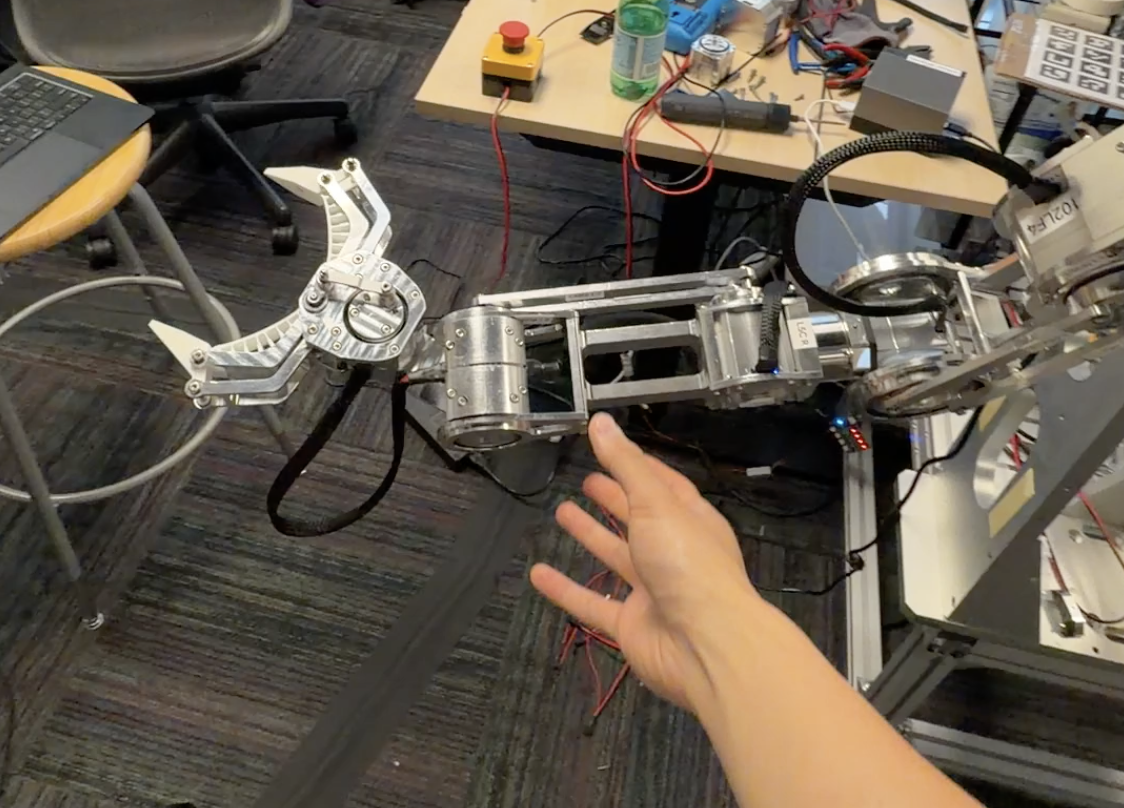
- Integrated URDFs and calibrated joint mappings, encoder directions, offsets, and torque limits for the new seven-DOF HighTorque arms.
- Tuned Pinocchio gravity compensation through single-joint and full-arm float tests, supporting 1 kHz local control over CAN FD.
- Characterized Coulomb friction and developed compensation profiles; some joints still needed validation.
Ethernet teleoperation
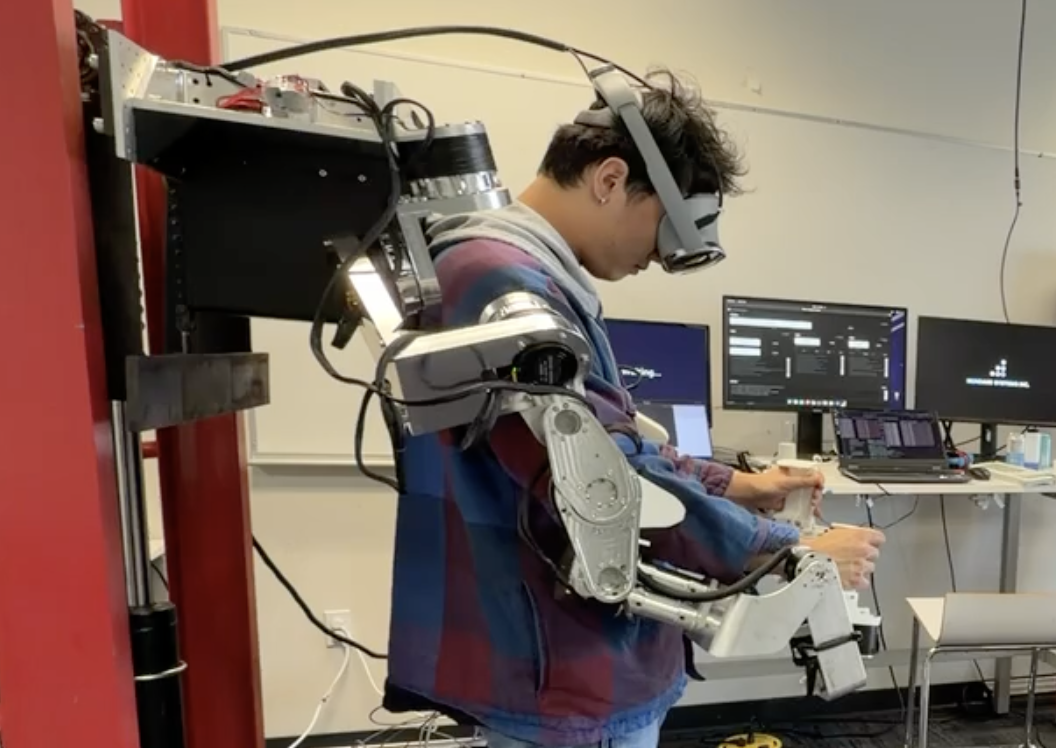
- Configured cross-machine ROS 2 communication, clock synchronization, and launch and diagnostic tools.
- Restored leader–follower tracking by fixing false dropout detection and holding the latest ~100 Hz reference between updates to the 1 kHz local controller.
- Added command-age checks to reject stale references and a controlled transition to a held pose on link loss.
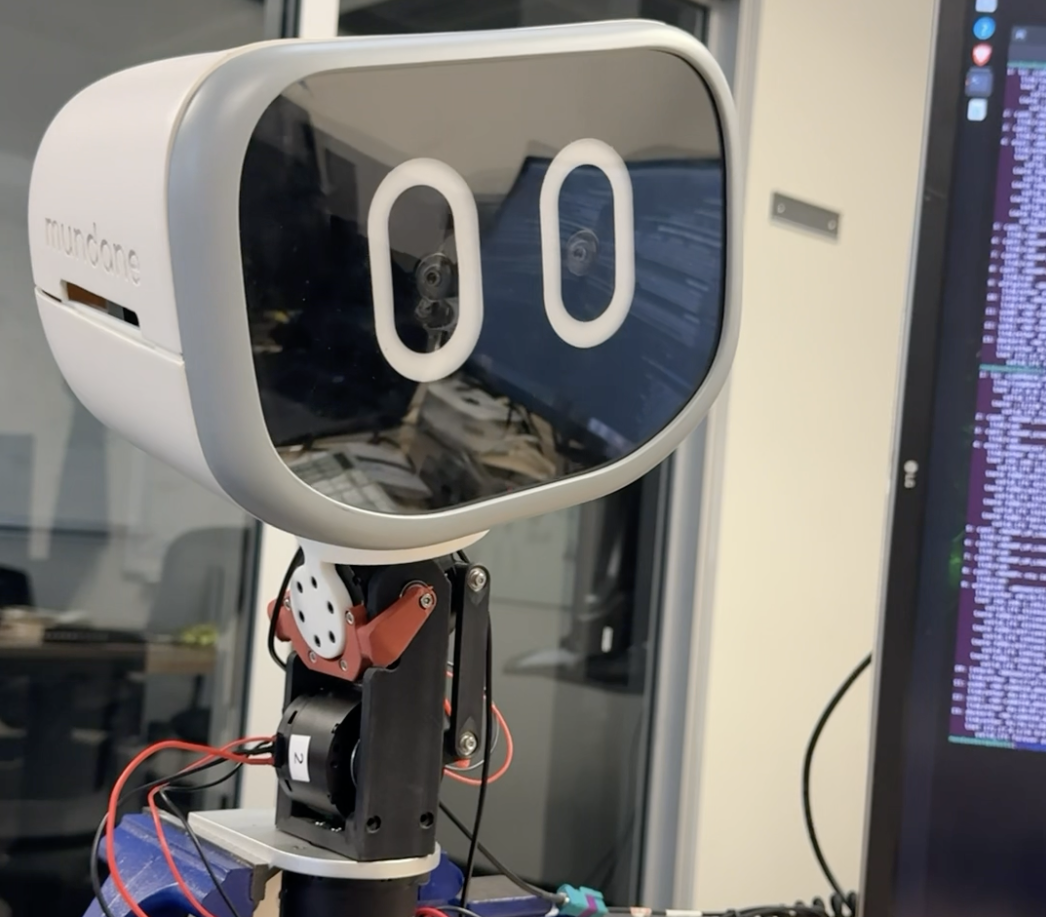
Headset-driven neck
- Converted headset orientation into calibrated joint targets for the three-DOF Damiao neck.
- Tuned PD control, orientation smoothing, and velocity/acceleration limits for smoother motion.
- Fitted sinusoidal gravity feedforward and built calibration and motion-logging tools.
Watch the public customer demo at NECA 2026 on LinkedIn →